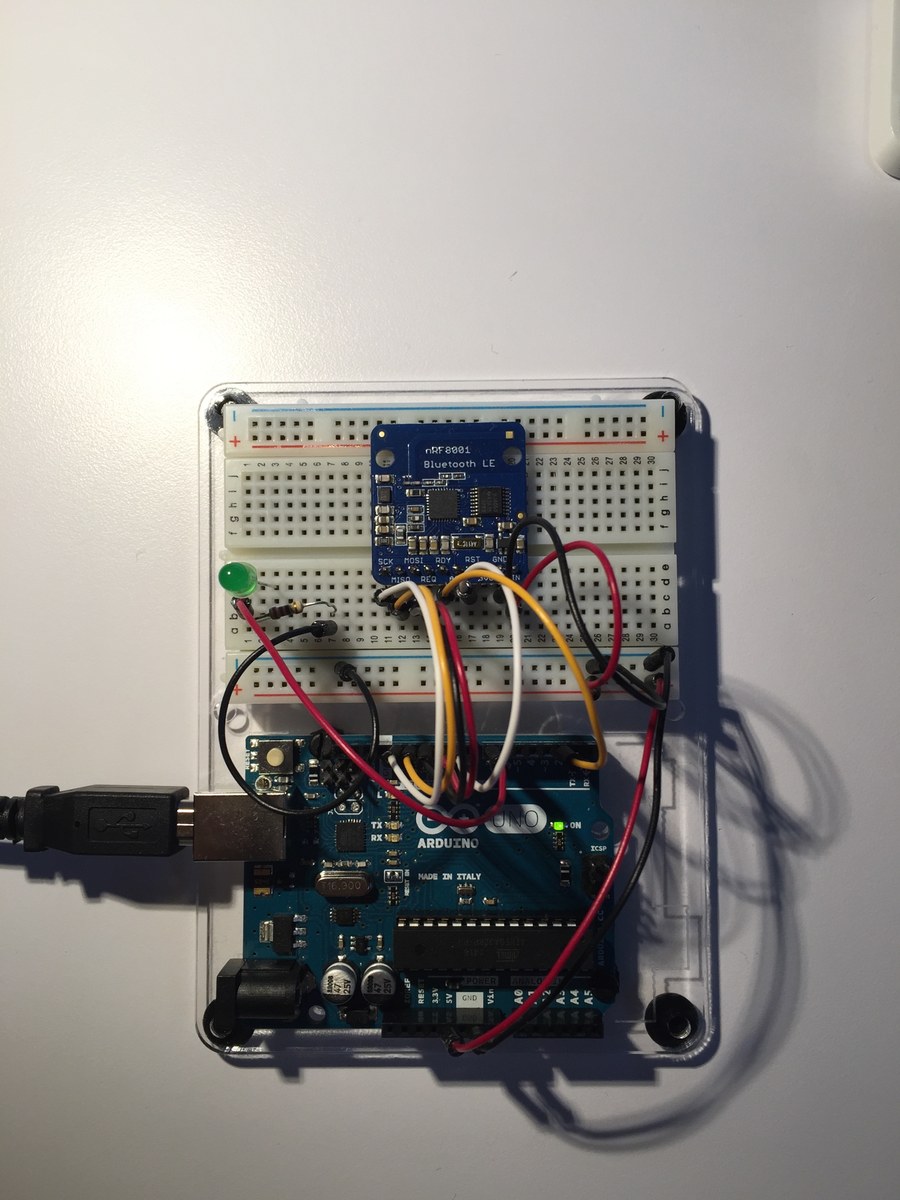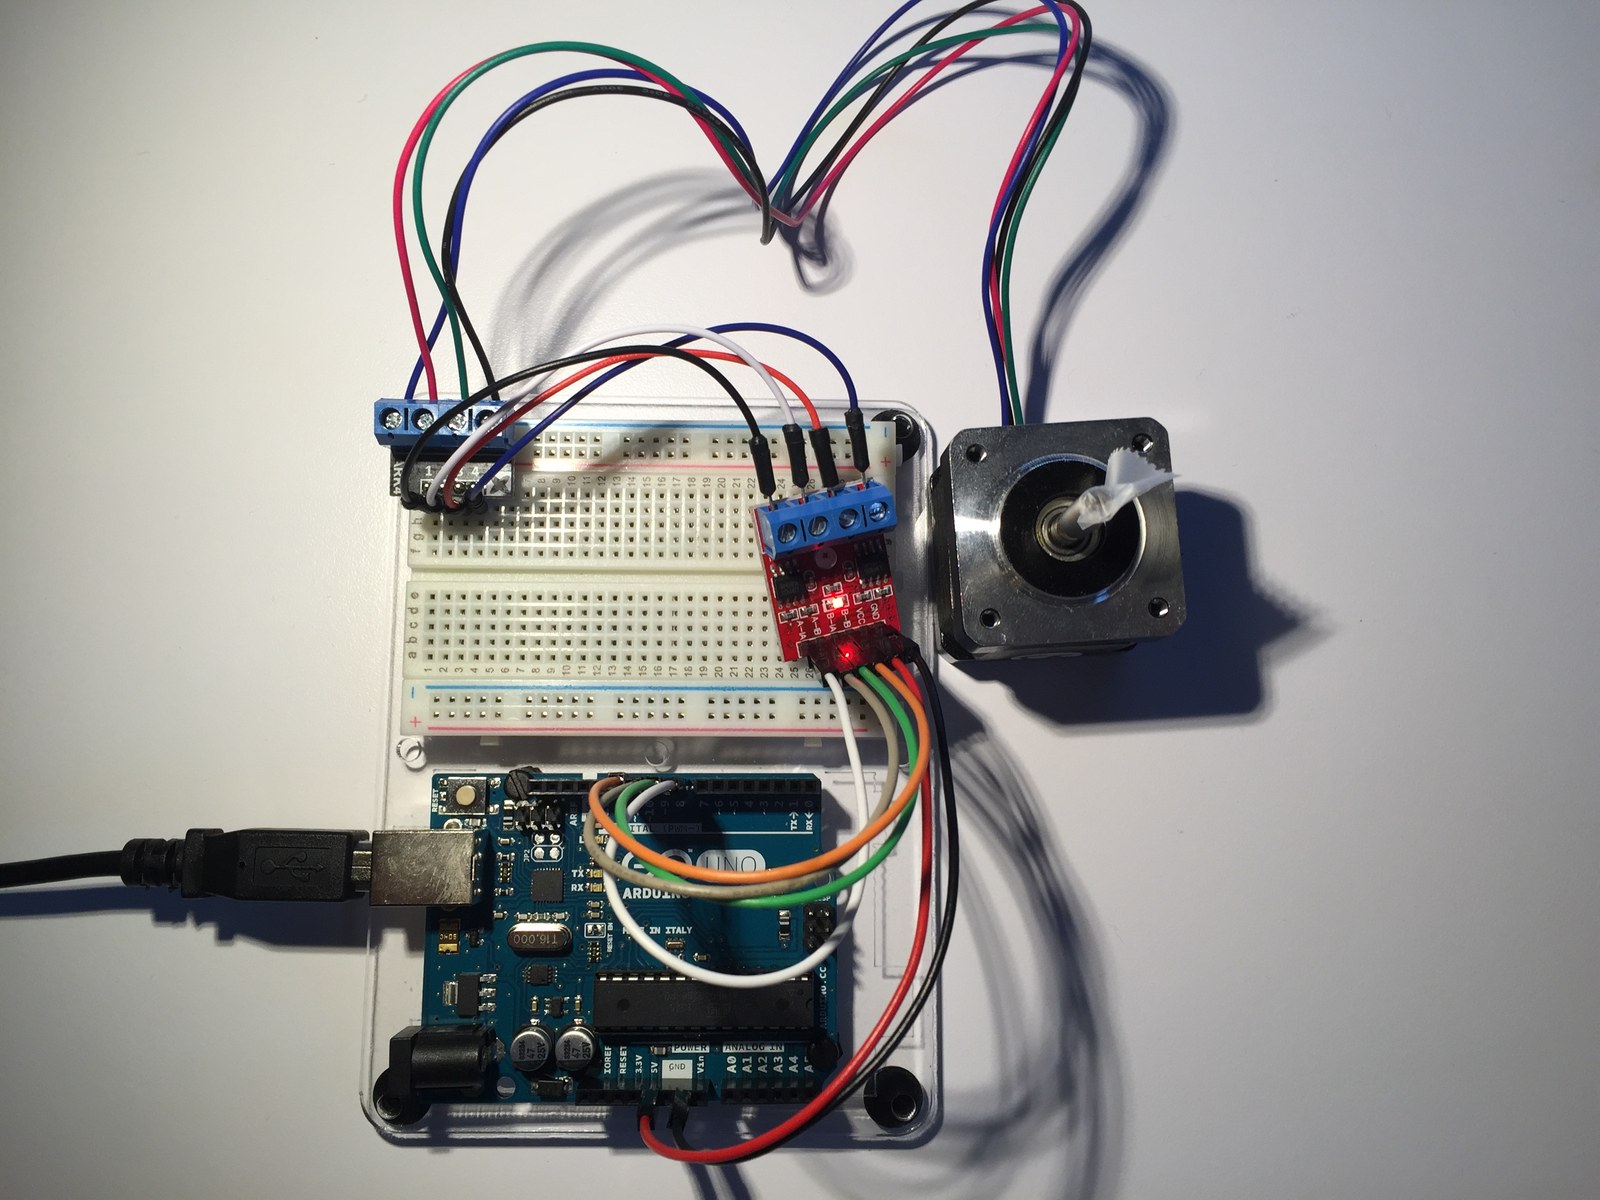
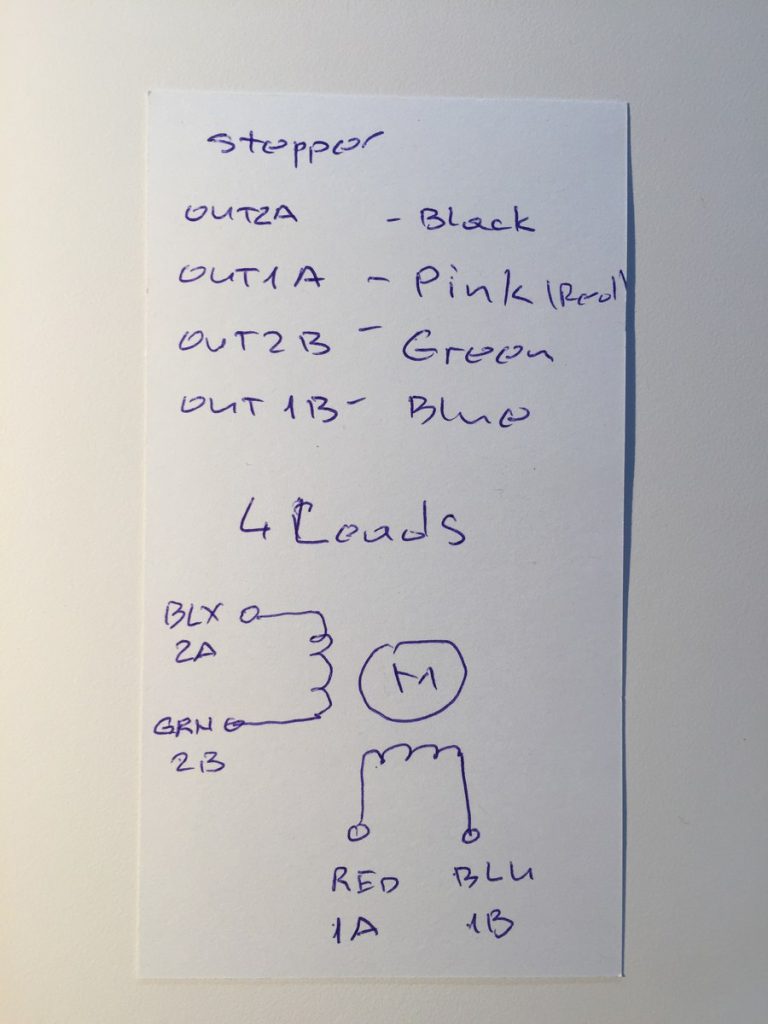
The stepper bench archive contains a motor demonstration, winding notes, a bipolar-motor datasheet and a sketch named Stepper_28BYJ_48. The combination is a useful reminder to check the actual code and motor configuration instead of relying only on a folder title.
How the project works
The sketch uses the Arduino Stepper library with 2,048 steps per revolution and a pin order of 8, 10, 9, 11. It requests 10 RPM, advances 1,024 steps, pauses for five seconds, then reverses by the same number of steps.
With the configured value of 2,048 steps per revolution, 1,024 steps is a half revolution. A comment describing two revolutions does not match that arithmetic. The photographs and bipolar datasheet describe the bench hardware, while the sketch parameters are those of the saved 28BYJ-48 example.
Hardware and configuration
| Item | In the supplied code |
|---|---|
| Library | Arduino Stepper |
| Constructor pin order | D8, D10, D9, D11 |
| Configured revolution | 2048 steps |
| Motion | +1024 / −1024 steps, with pauses |
Working with the supplied code
Identify the winding pairs and driver type before reusing the example. A bipolar motor and a geared 28BYJ-48 do not share interchangeable winding and step-count assumptions.
Begin with a modest speed and a small movement after setting the correct coil order. Compare the direction and distance to the intended mechanical motion, then adjust the steps-per-revolution setting for the motor and gearing actually fitted. The saved video records the original bench demonstration; it is not a calibration of every configuration in the folder.
Video demonstration
Source code and project files
Browse this project on GitHub. The files below are useful starting points for the sketches and references discussed in this post.
Download the used libraries (ZIP, 14.7 MB).
These notes describe the archived source and project media. The sketches have not been rebuilt or tested on hardware for this article.